qiBullet
a Bullet-based simulator for the robots
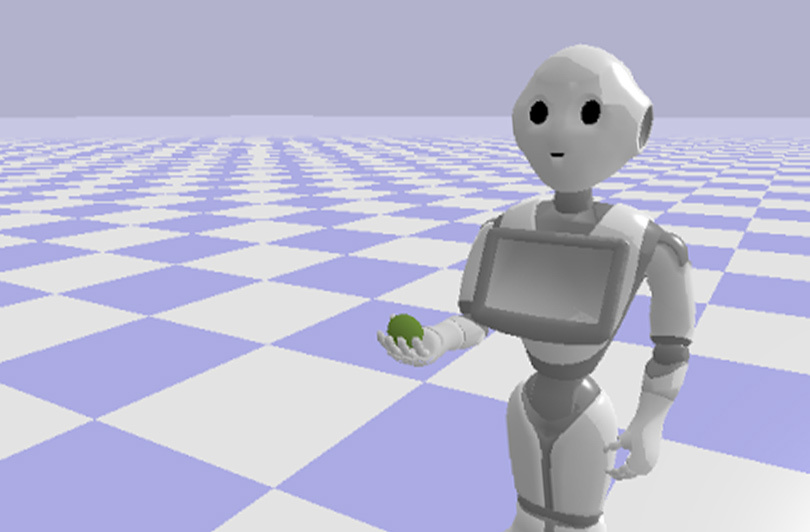
qiBullet is a simulation tool enabling users to easily experiment with Pepper and NAO robots in virtual environments and gather accurate data.
In robotics, many different tasks drive the developer to gather data by iteratively repeating specific tasks with a robot. This data could, for instance, be used to validate the behavior of the robot for a specific scenario, or train machine learning algorithms. The data gathering task is often time consuming and can also damage the robotic platform.
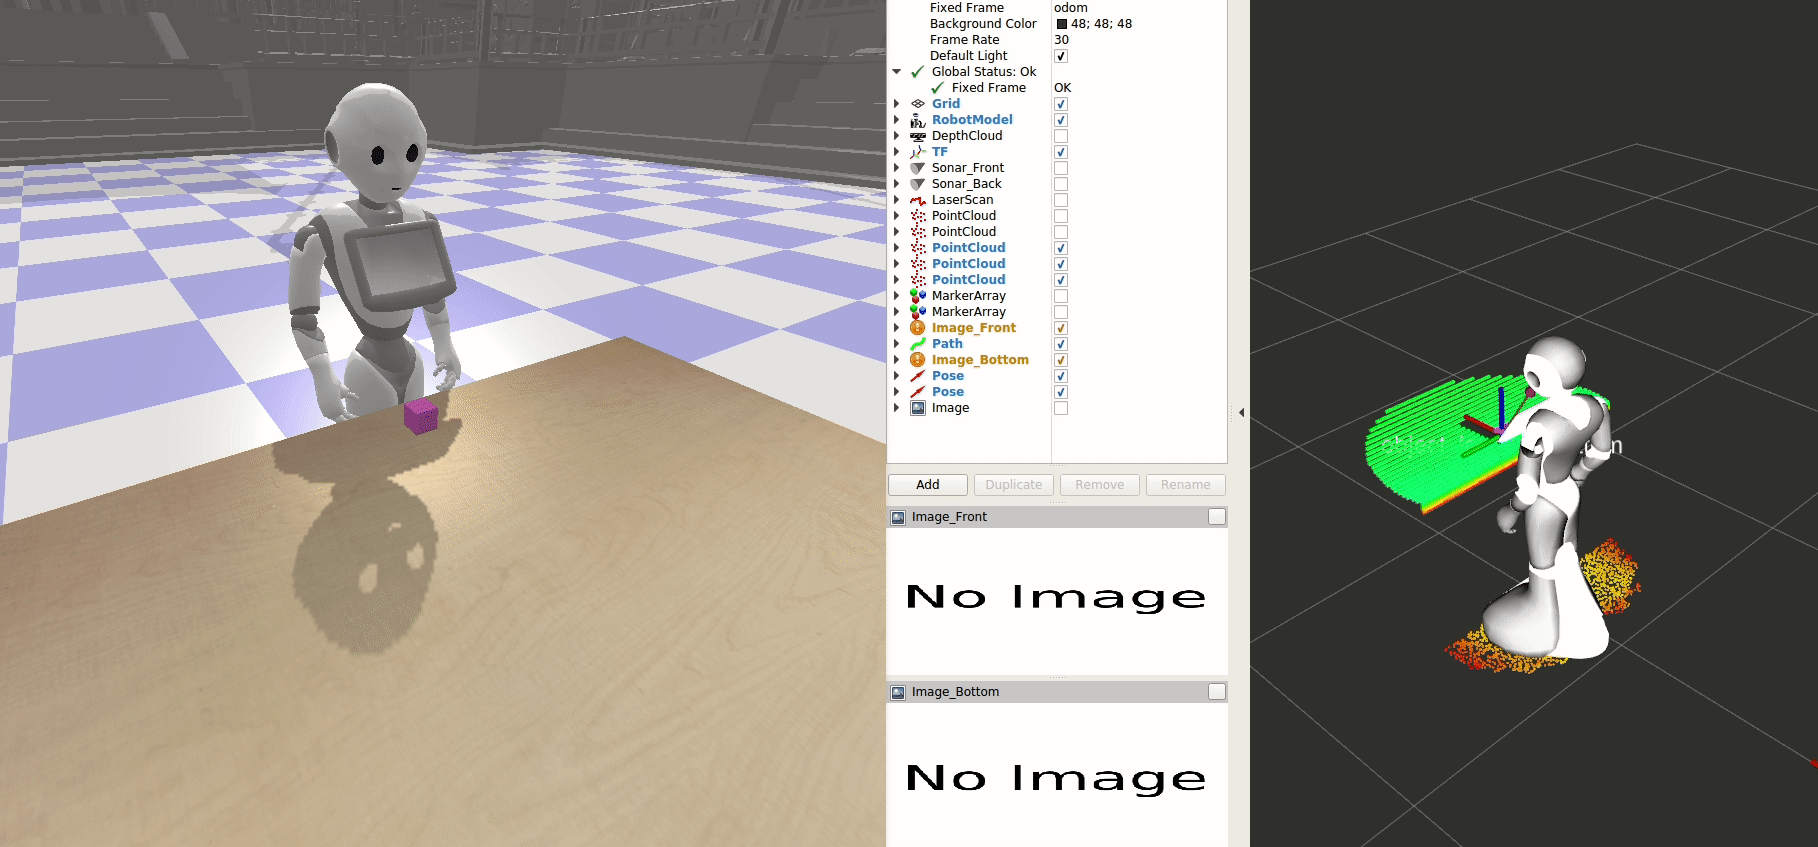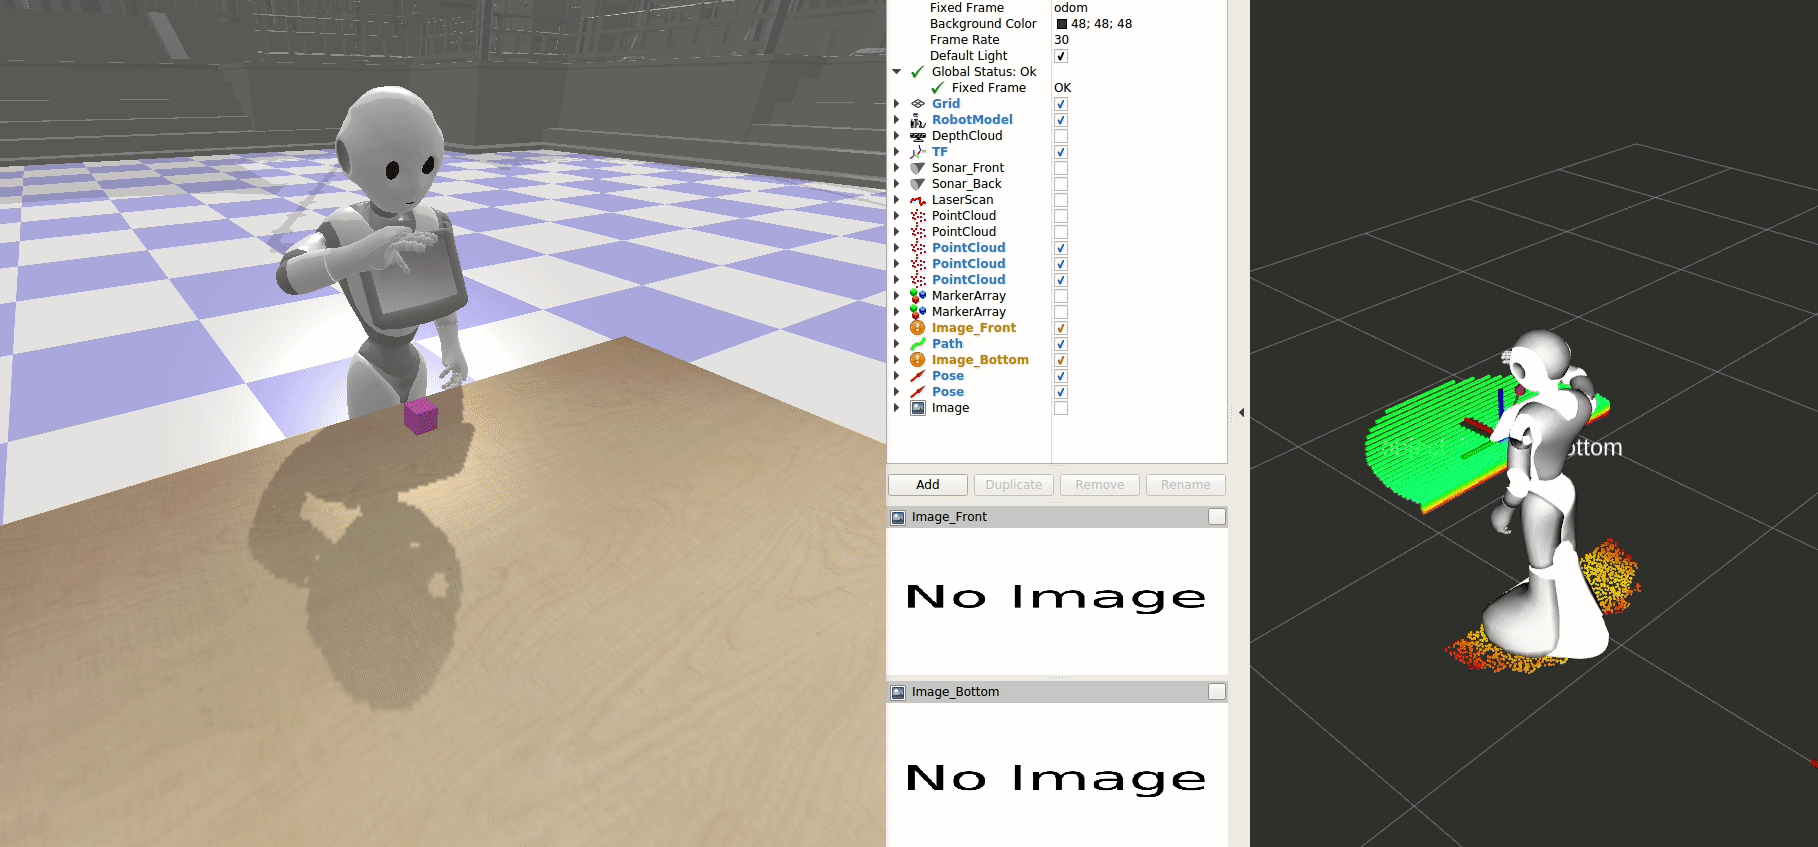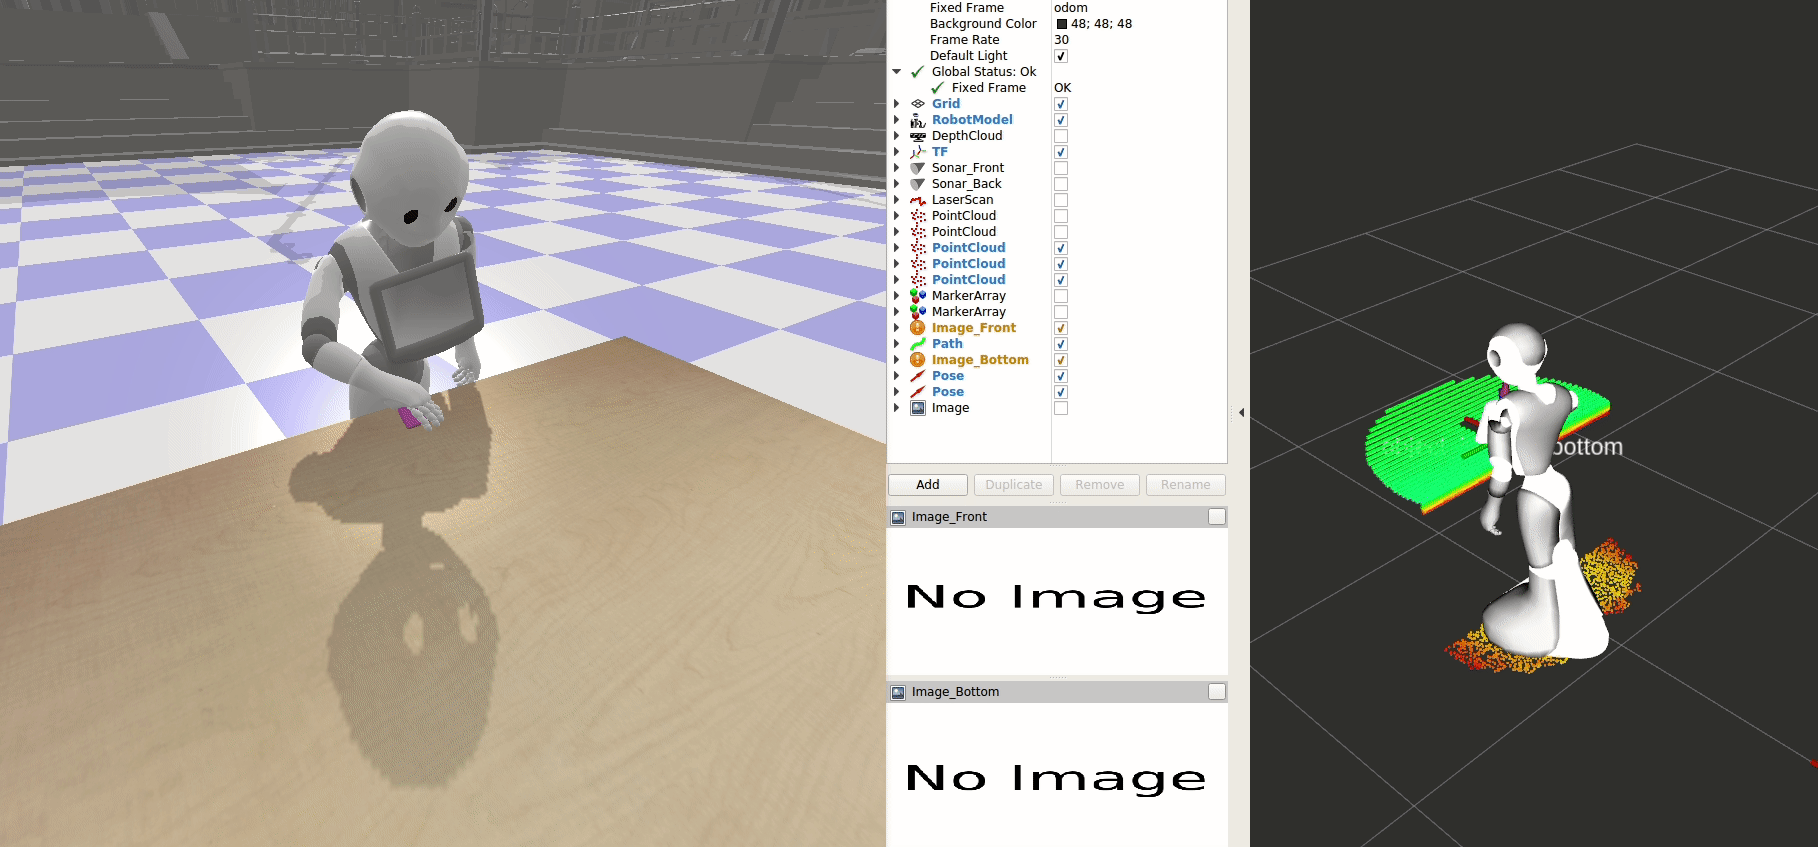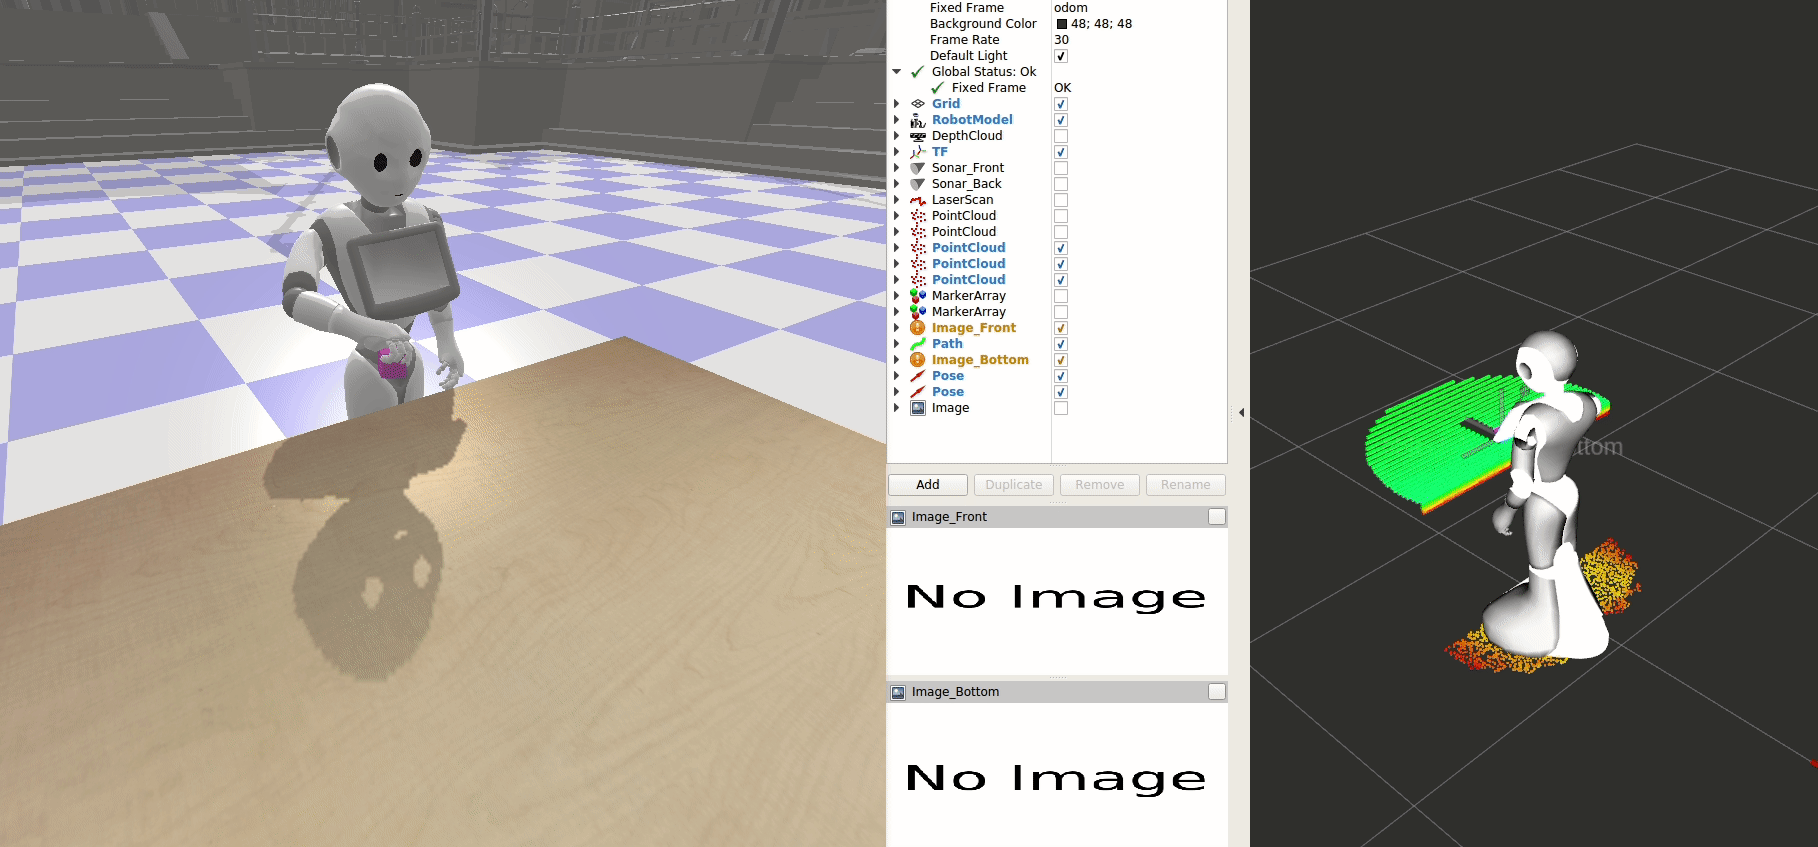
The goal of qiBullet is to provide a physically accurate simulation tool for SoftBank’s robots, based on the Bullet physics engine, that would ease this data gathering task. The simulator is open-source, cross-platform and allows developers to embed a virtual robot in different environments, via a Python-based API or a ROS interface.
 * qiBullet Github repository
* Paper
* qiBullet wiki (and tutorials)
* API documentation